TidyVerse

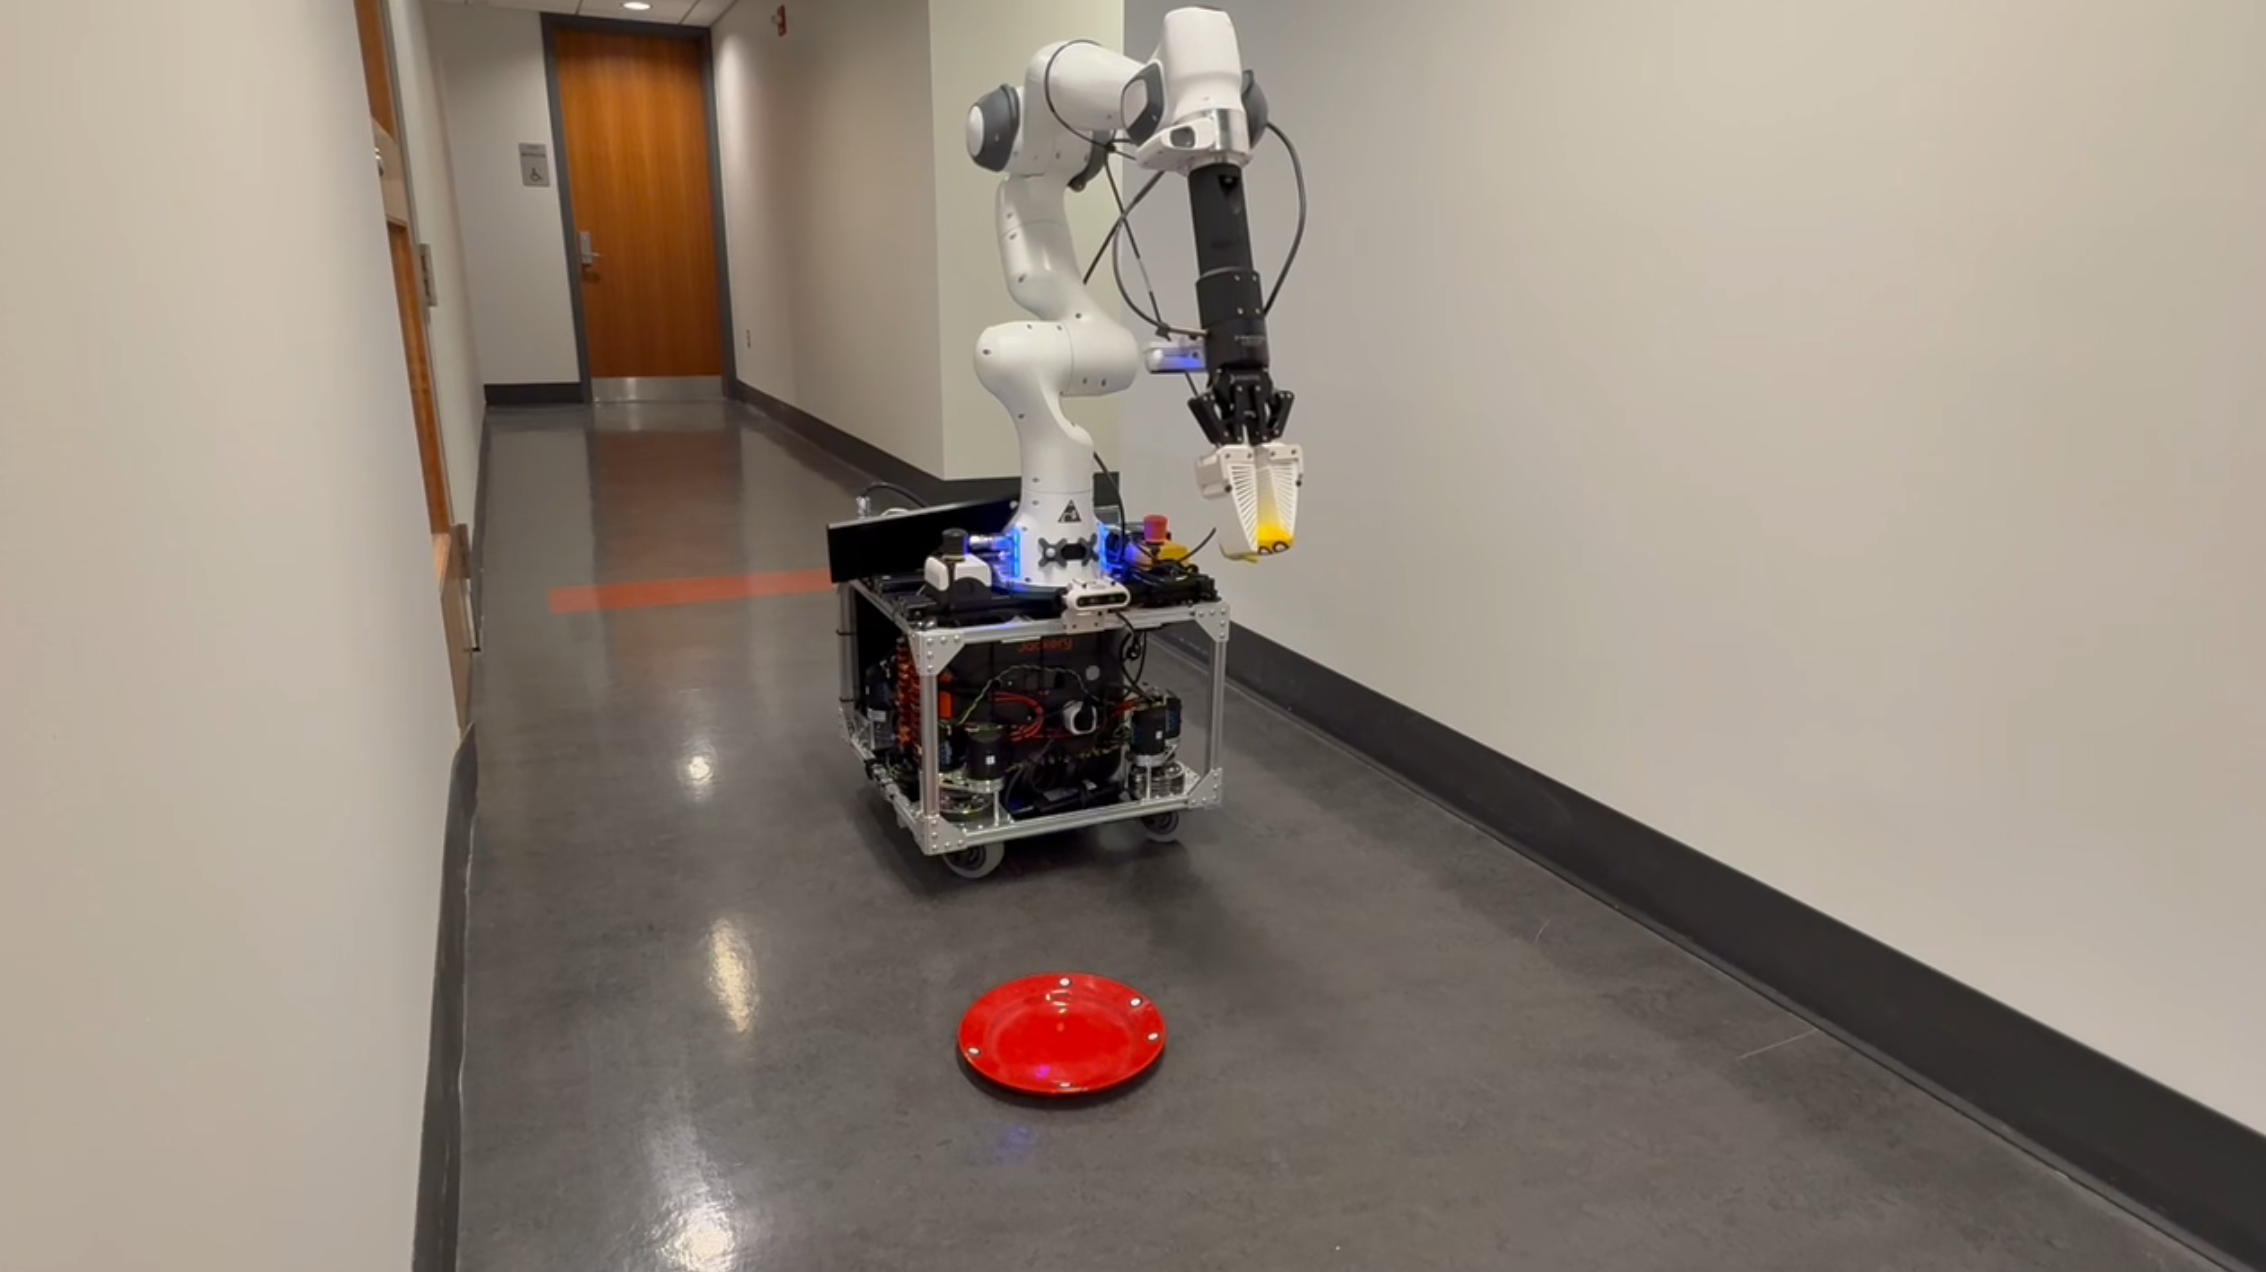
A high-payload mobile manipulation platform that combines a holonomic base with a 7-DoF arm. 

High-Payload Platform

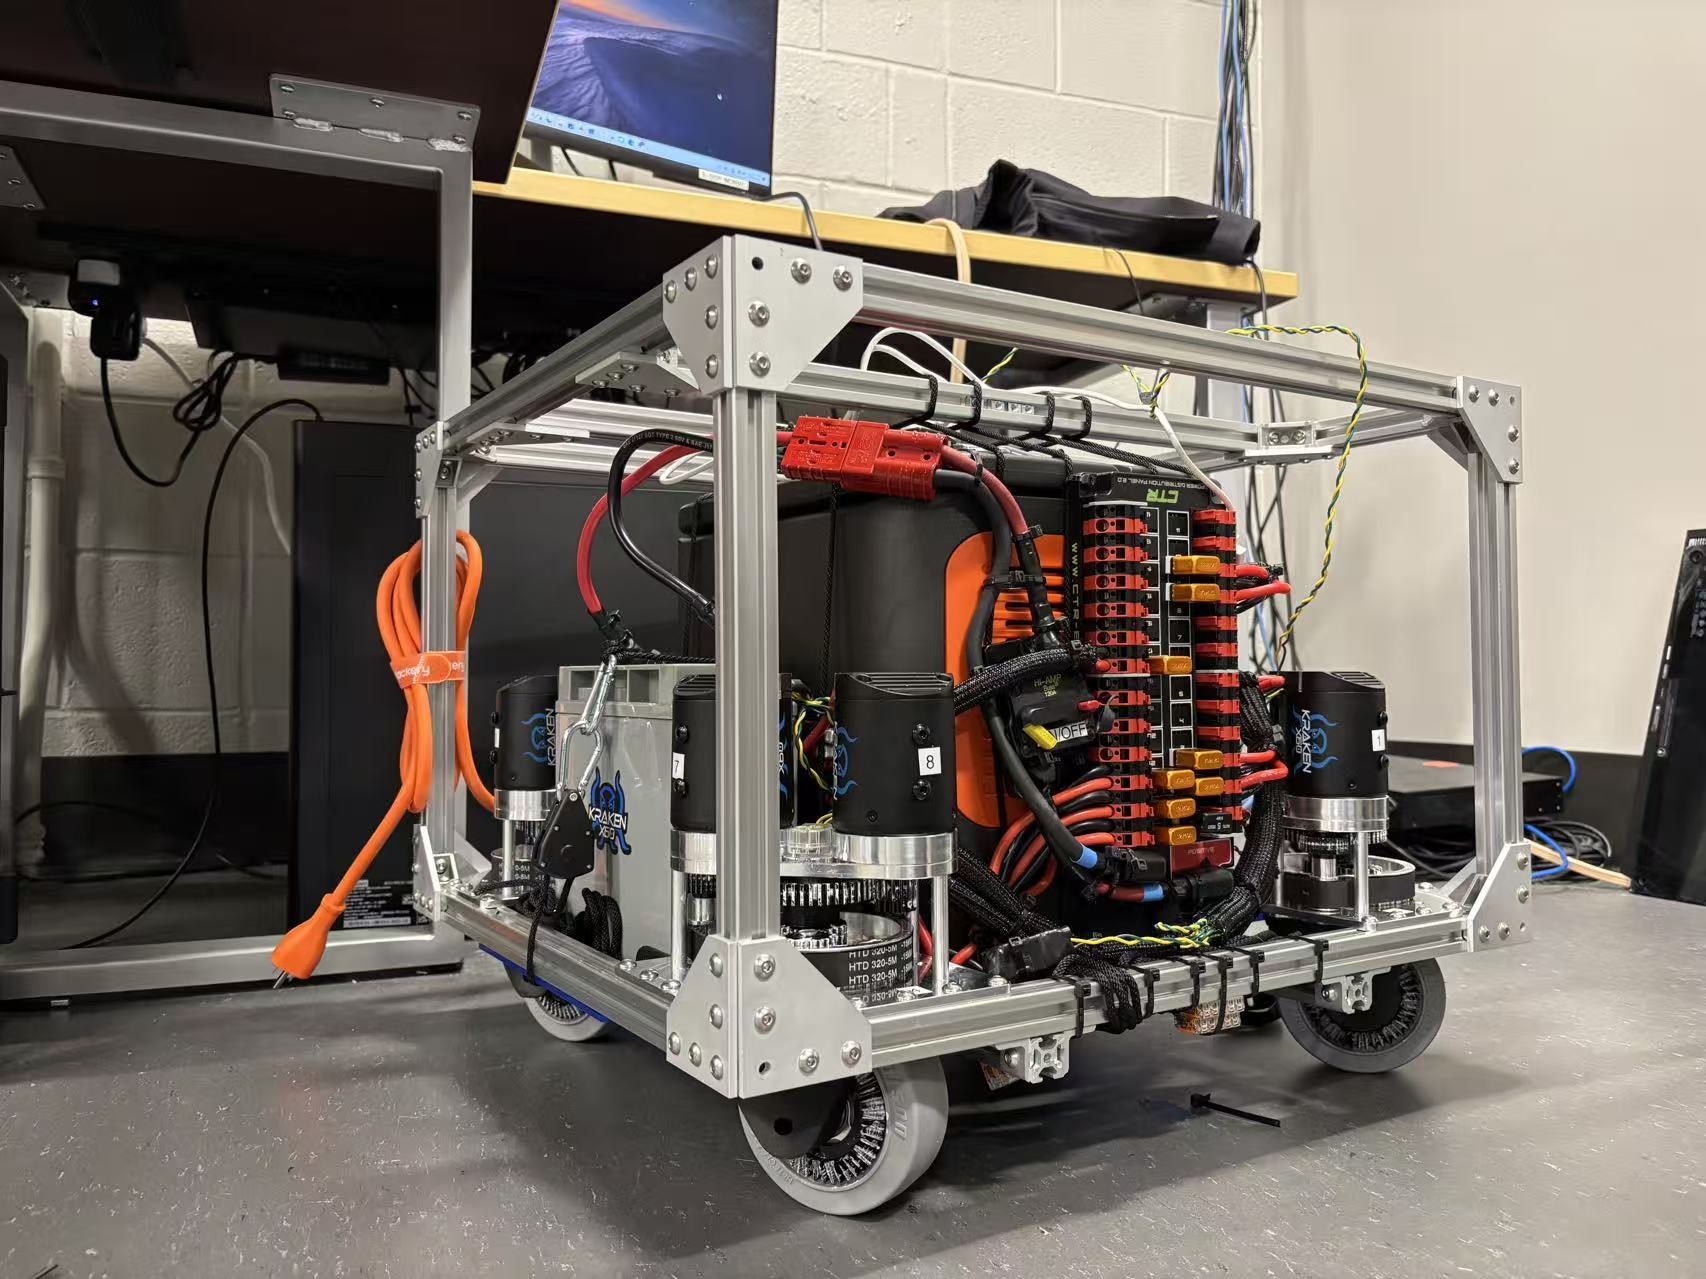
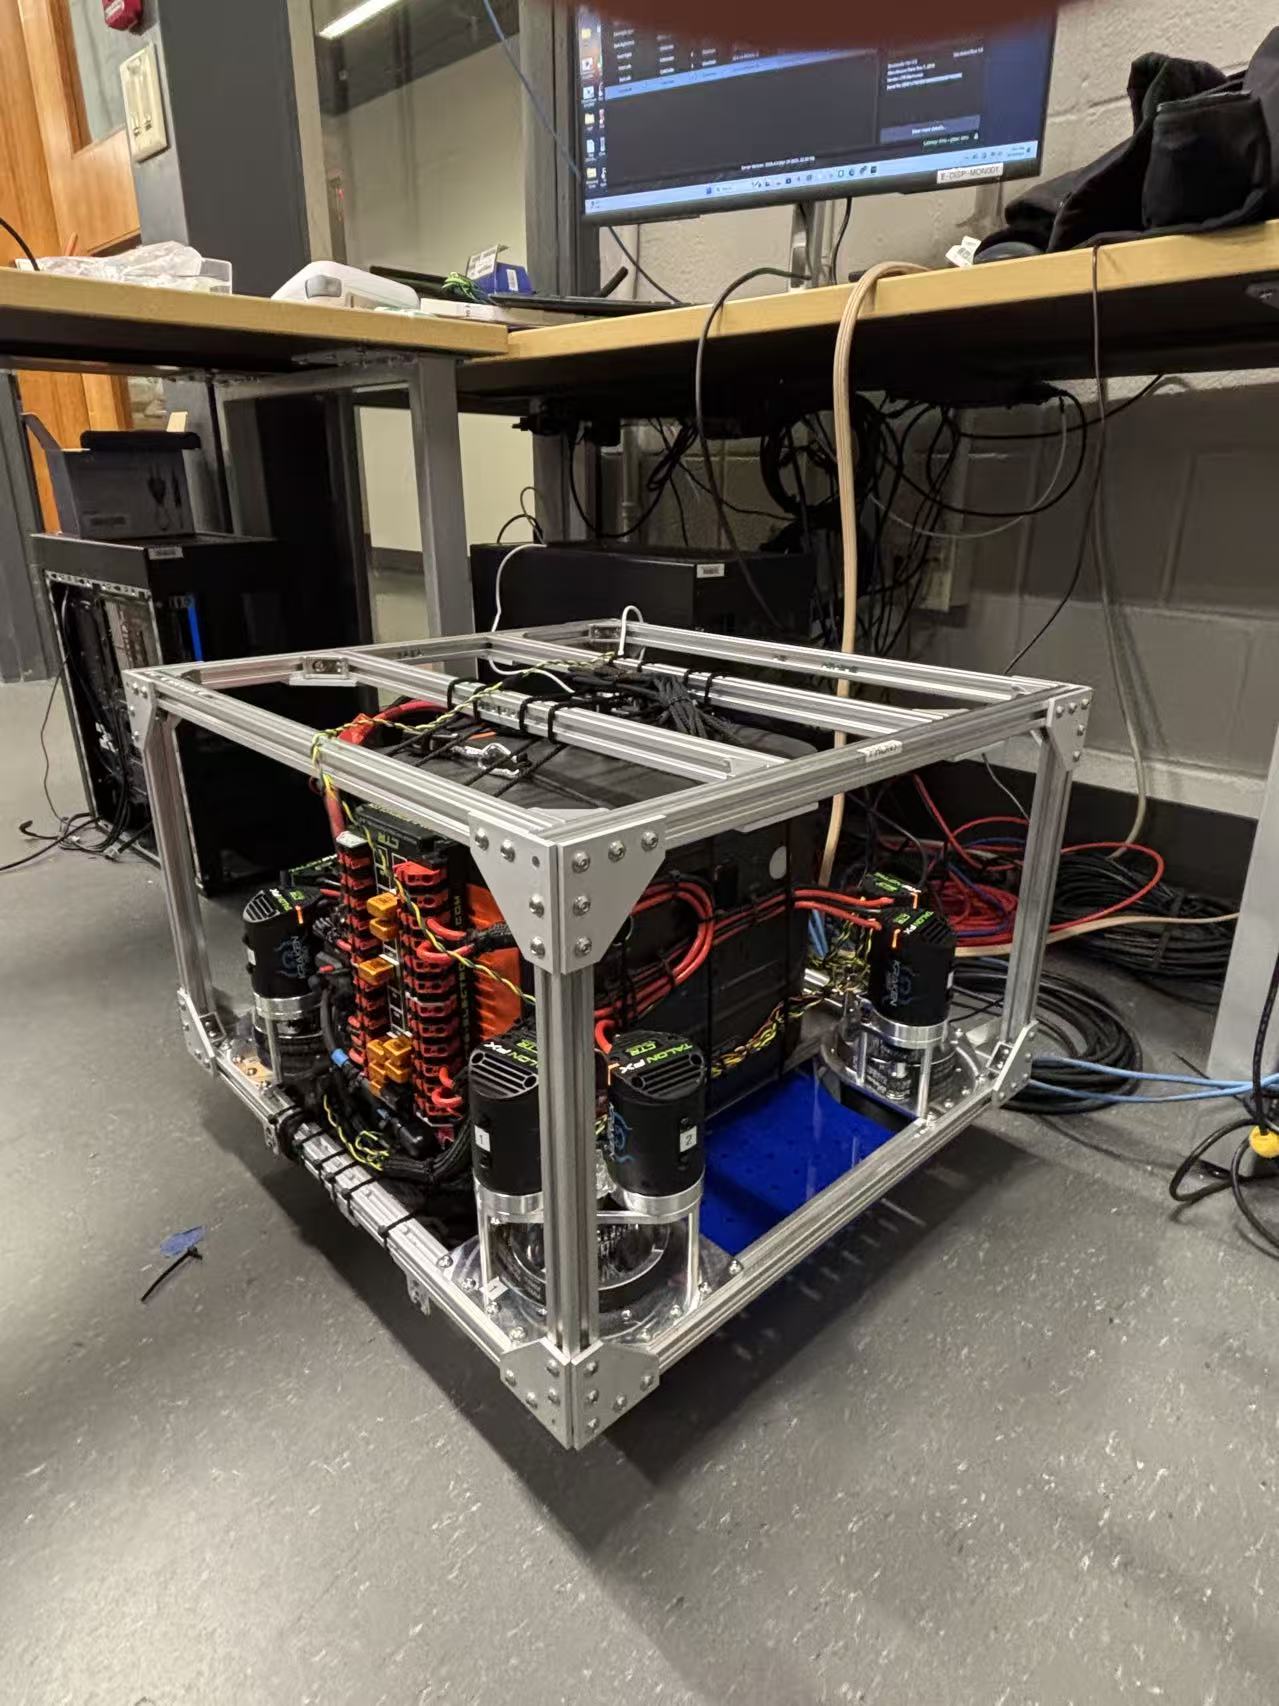
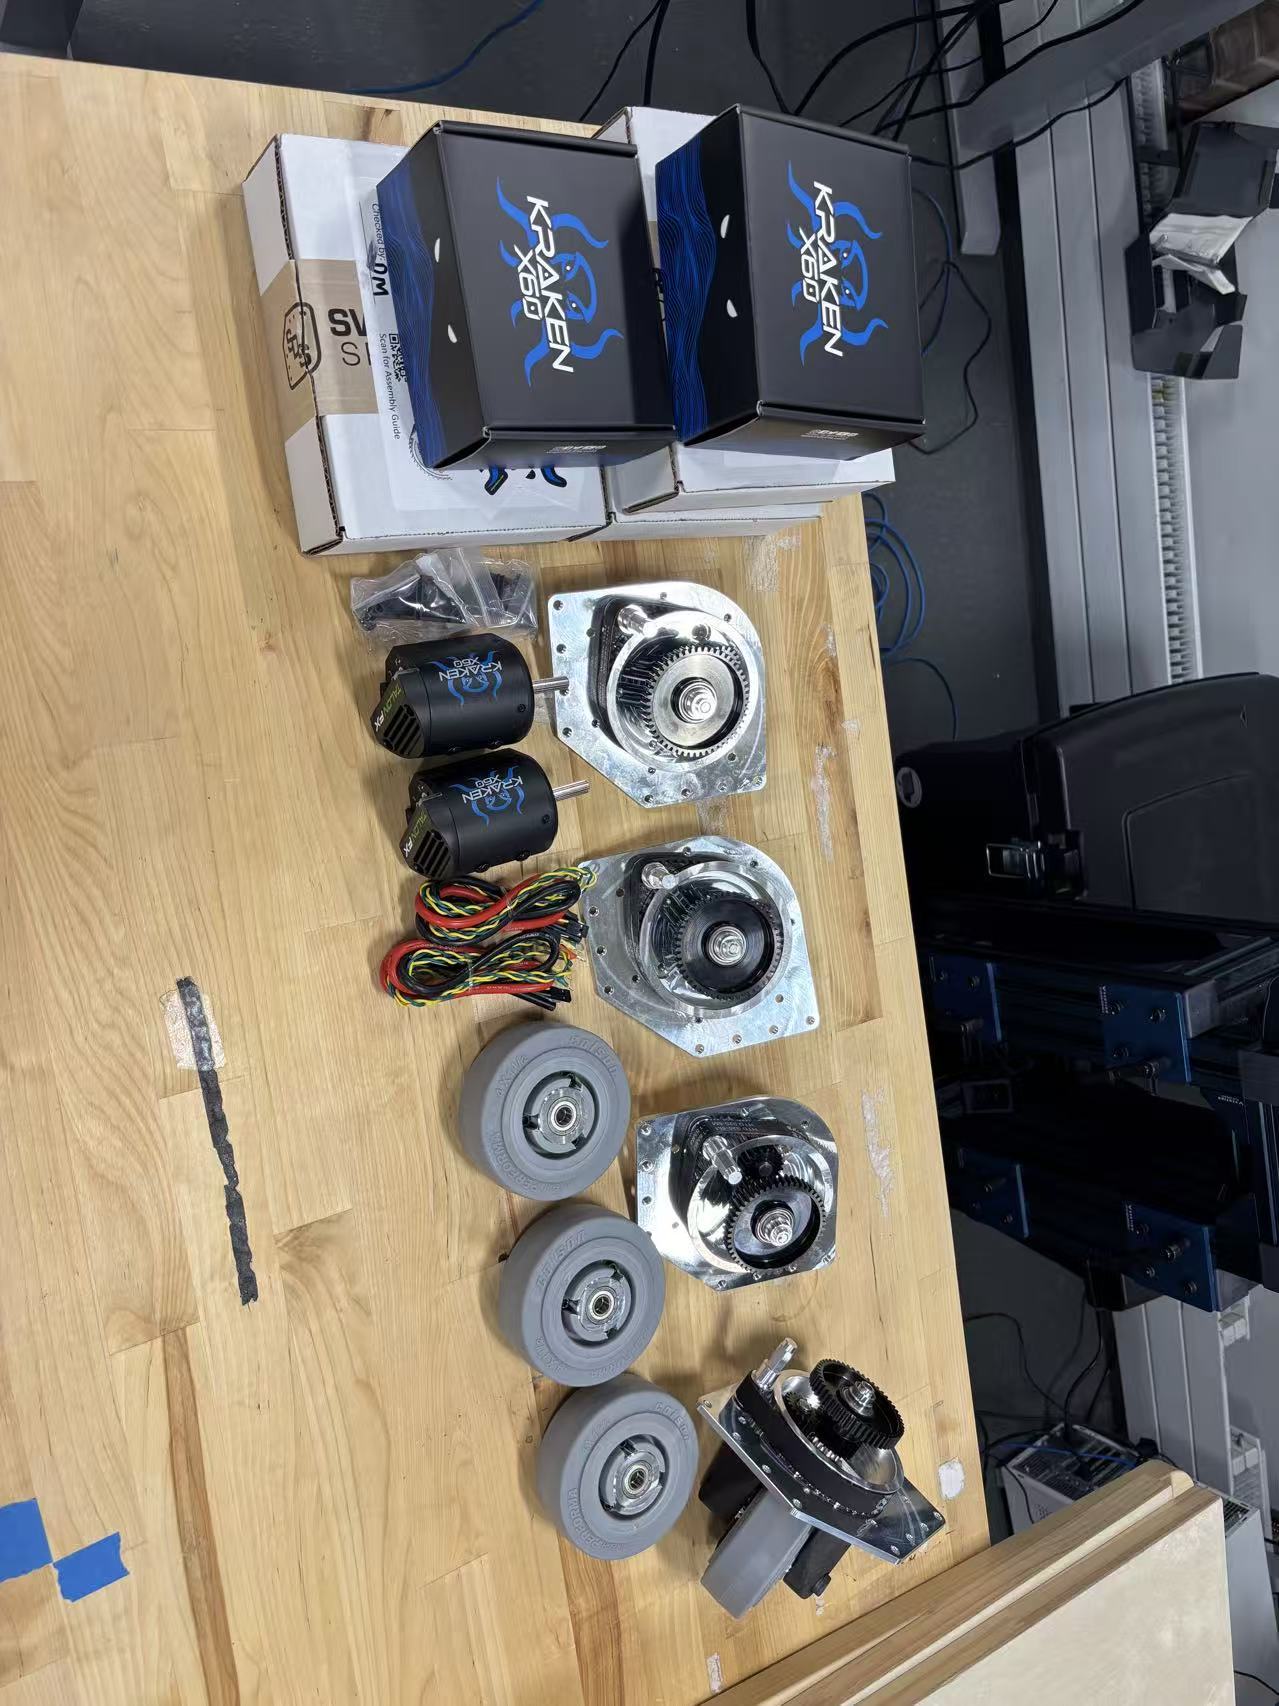
A high-payload holonomic base provides omnidirectional mobility and supports interchangeable 7-DoF arms, including the Franka Panda and KUKA LBR iiwa 7. 

Full-System Simulation

A complete URDF model of the mobile base and robotic arm was implemented. Providing a simulation environment for developing and validating the whole-body controller. 

Whole-Body Control

A QP-based velocity controller coordinates the arm and mobile base as a unified system, enabling smooth end-effector pose tracking across an extended workspace. 

OpenClaw Autonomy

OpenClaw converts high-level instructions into task sequences executed by the backend perception, base, and arm controllers. If a joint exceeds its user-defined limits, controller-level safeguards reverse its motion until it returns to the safe region.